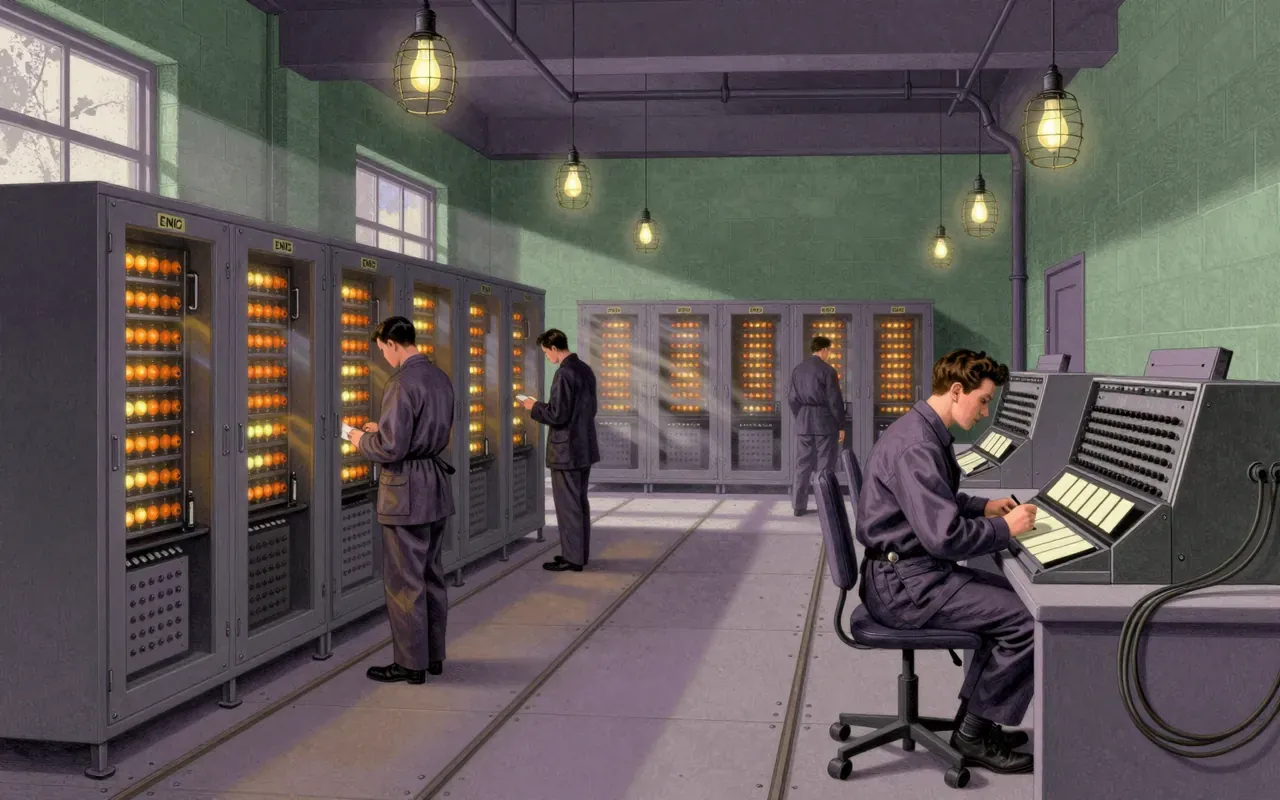
A physics engine is software that approximates classical mechanical systems—rigid, soft, and fluid—using computational models. It solves the problem of predicting motion and interaction where analytical solutions are intractable. Real-time engines simplify calculations to meet frame-rate deadlines. High-precision engines use more processing power for accuracy, targeting science and film. ENIAC applied basic physics modelling to ballistics, assigning mass, angle, charge, and wind drift to compute trajectories. Since the 1980s, supercomputer-based engines have modelled fluid dynamics by assigning force vectors to particles. It does not simulate quantum or relativistic effects. It does not eliminate approximation: all outputs are estimates, not measurements. ENIAC produced one-time printed tables—not live feedback. Real-time engines sacrifice accuracy by design; high-precision engines cannot run interactively. It replaces manual calculation and physical experimentation with repeatable, scalable computation. It shifts ballistics from artillery field tables to real-time targeting systems. It enables visual effects pipelines that decouple simulation from rendering. It makes fluid behaviour programmable—but only as particle aggregates, not continuous media. Rigid-body collision detection works reliably in games. Ballistics table generation worked on ENIAC for fixed artillery conditions. Particle-based force vector modelling works for large-scale fluid circulation on supercomputers. Real-time response works when accuracy is secondary to latency.
historians studying early computational ballistics
Skip it if
physicists requiring exact differential solutions
real-time control engineers needing deterministic latency
Who should study it, and who should skipHide who it is for
The written brief1 min read
What it is and the problem it solves
A physics engine is software that approximates classical mechanical systems. It solves the problem of predicting motion and interaction where analytical solutions are intractable—like shell trajectories or airflow around a wing.
How it works
A physics engine approximates classical dynamics—rigid, soft, and fluid systems—using computational models. Real-time engines simplify calculations to meet frame-rate deadlines. High-precision engines use more processing power for accuracy, targeting science and film. ENIAC applied basic physics modelling to ballistics, assigning mass, angle, charge, and wind drift to compute trajectories. Since the 1980s, supercomputer-based engines have modelled fluid dynamics by assigning force vectors to particles.
What works
Rigid-body collision detection works reliably in games. Ballistics table generation worked on ENIAC for fixed artillery conditions. Particle-based force vector modelling works for large-scale fluid circulation on supercomputers. Real-time response works when accuracy is secondary to latency.
What does not
It does not simulate quantum or relativistic effects. It does not eliminate approximation: all outputs are estimates, not measurements. ENIAC produced one-time printed tables—not live feedback. Real-time engines sacrifice accuracy by design; high-precision engines cannot run interactively.
What it changes
It replaces manual calculation and physical experimentation with repeatable, scalable computation. It shifts ballistics from artillery field tables to real-time targeting systems. It enables visual effects pipelines that decouple simulation from rendering. It makes fluid behaviour programmable—but only as particle aggregates, not continuous media.
Is it worth your time
Yes—if your work demands either real-time interactivity or high-fidelity simulation. No—if you need exact physical prediction without approximation, or if you expect a single engine to serve both domains well. The trade-off between speed and precision is structural, not temporary.