What it is and the problem it solves
Haptic technology is engineered touch: it solves the problem of conveying physical sensation without physical contact. It bridges the gap between digital representation and somatic response—where sight and sound fall short.
How it works
Haptic technology creates touch experiences by applying forces, vibrations, or motions. It incorporates tactile sensors to measure user-applied forces. It enables controlled haptic virtual objects for studying human touch perception.
What works
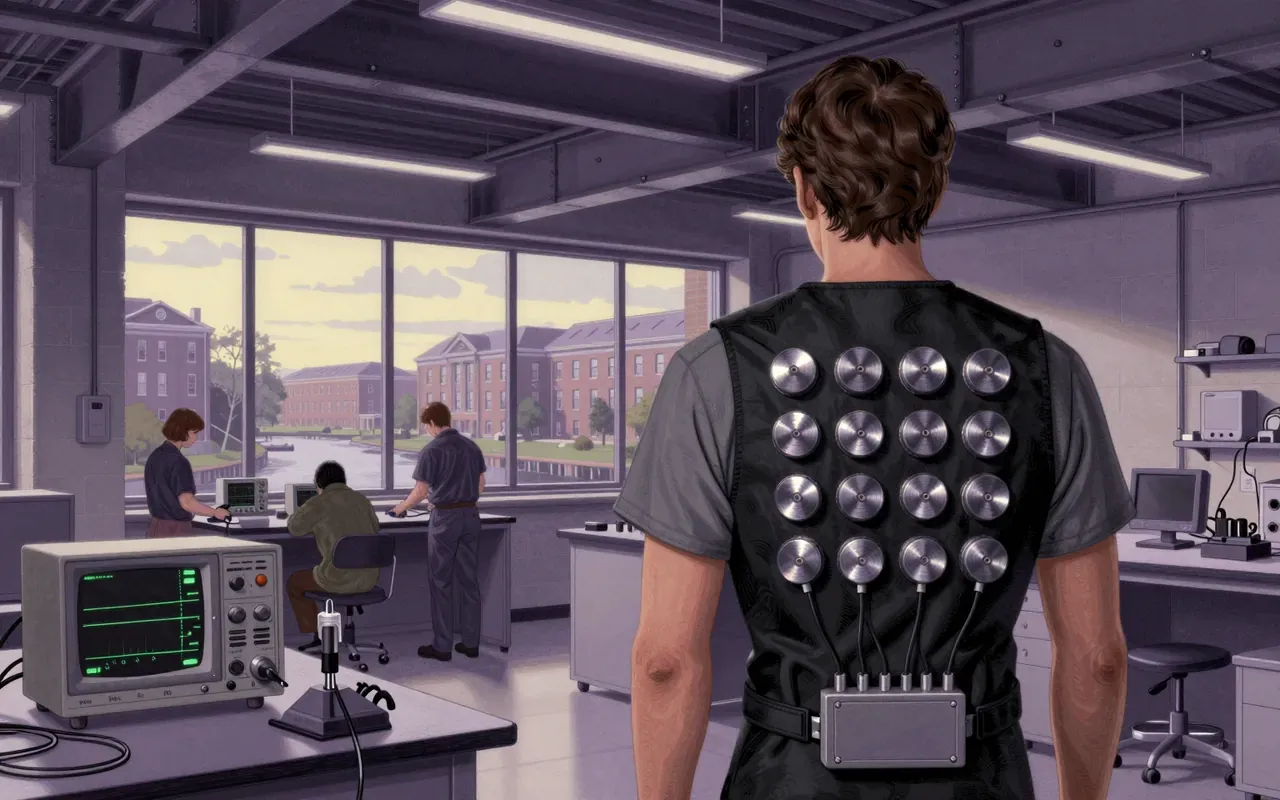
Force-feedback interfaces enable precise remote machine control. Tactile sensors on haptic devices capture user input forces. Vision substitution systems (1960s) proved discrete tactile arrays can convey spatial information. The 1973 tactile telephone patent established early actuation for communication. The 1994 Aura Interactor vest demonstrated real-time audio-driven haptics in wearable form.
What does not
It does not deliver realistic, high-resolution touch across surfaces or textures. It does not generalise across modalities: a vibration representing a punch is not equivalent to feeling impact, friction, or temperature. It does not scale to full-body, multi-point, low-latency feedback outside niche hardware.
What it changes
It changes how machines are remotely operated—adding force cues to teleoperation. It changes how touch is studied—replacing uncontrolled physical stimuli with programmable, repeatable haptic events. It changes audio-to-haptics translation—converting bass frequencies into action-linked vibrations, as in the 1994 Aura Interactor vest.
Is it worth your time
Yes—if you work in telerobotics, VR interaction design, or sensory neuroscience. No—if you expect broad tactile fidelity in consumer devices. The gap between lab-controlled virtual objects and real-world tactile feedback remains wide.