Saved
Robotics

Industrial robot

Industrial robots didn’t arrive with AI—they arrived with paper tape, solenoids, and a single-minded refusal to tire.

Worth your time?4/5Yes.Study the whole thing.What works, what does not, who it is for ↓
9:47in productionCh. 1 · Paper tape and solenoids/ 9:47 · ceiling 15 min
4 chapters · 9:47Ceiling 15:00

The brief is written and checked. The video joins this page when it is cut.4 chapters · 1 min read · 9:47 planned

Read the brief

Industrial robots are programmable mechanical manipulators built to perform repetitive industrial tasks with precision and endurance. Their core innovation is not autonomy, but repeatability through deterministic actuation and external sequencing.

Chapters & takeaways4
  1. 0:53
    Paper tape and solenoids

    The first industrial robot was electromechanical, not digital—programmed by paper tape, not code.

  2. 2:20
    Patents before products

    Patents and companies came before working prototypes—Devol’s 1954 filing preceded Unimation’s first robot by years.

  3. 3:37
    Six axes, one solution

    The six-axis electric arm became the architectural standard—not because it was optimal, but because it enabled closed-form inverse kinematics.

  4. 5:21
    Convergent design

    Stanford and KUKA built functionally similar robots within four years—proof that the mechanical architecture had converged, not diverged.

1 more chapterFewer chapters
Worth your time?

Yes. Study the whole thing.

4/ 5
What works
  • axis-based articulation
  • solenoid-driven control
  • microprocessor sequencing
  • six-axis kinematic solution
What does not
  • learn
  • perceive
  • adapt
Study it if
  • manufacturing engineers
  • control systems designers
  • industrial historians
Skip it if
  • AI researchers
  • software developers
  • product managers
Who should study it, and who should skipHide who it is for
The written brief1 min read

What it is and the problem it solves

An industrial robot is a reprogrammable, multifunctional manipulator designed for material handling, welding, assembly, or painting in factory environments. It solves the problem of inconsistent, fatiguing, or unsafe manual repetition.

How it works

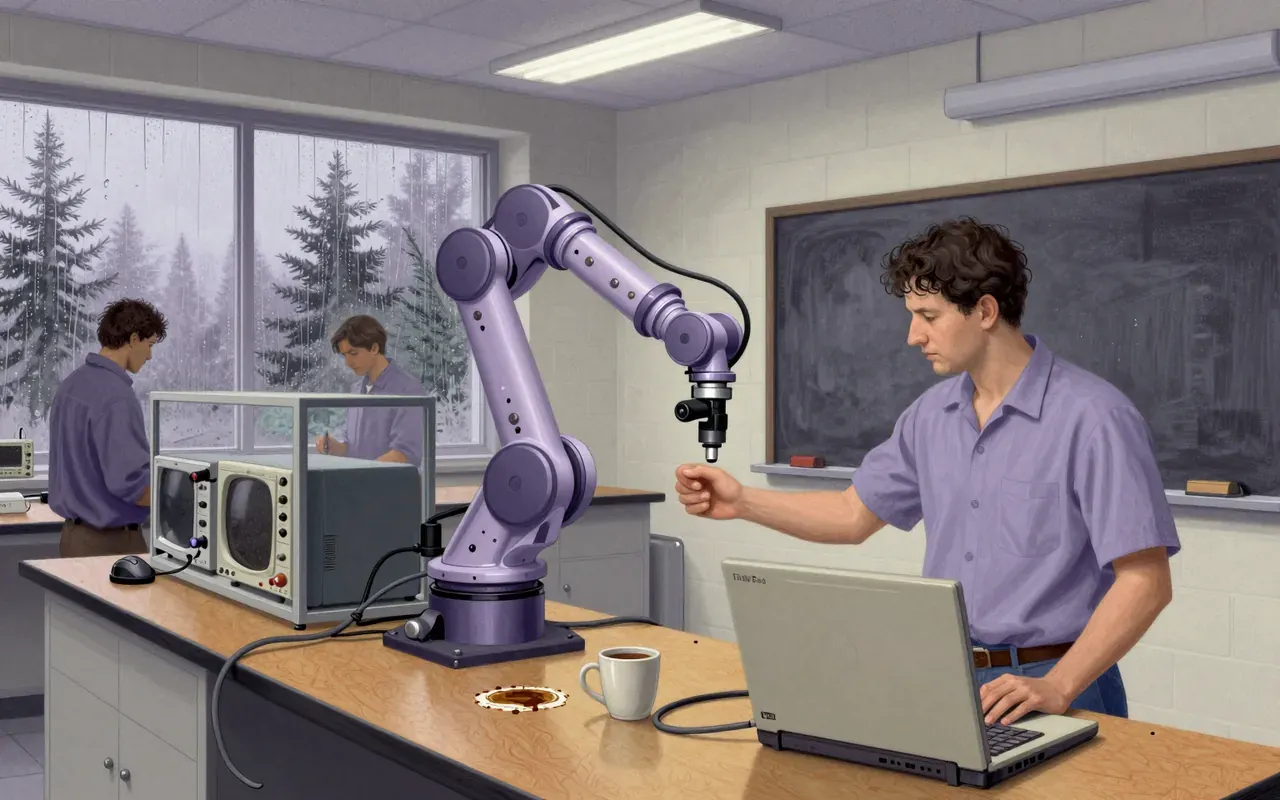
It moves via programmable mechanical arms with multiple axes of motion. Early versions used punched paper tape to trigger solenoids that moved crane levers. Later models used microprocessors and electric motors for precise, repeatable articulation.

What works

Axis-based articulation works. Solenoid-driven control levers worked in 1937. Microprocessor-controlled electric actuation worked by 1973. Six-axis electric arms enabled full spatial reach and tool orientation.

What does not

It does not think, adapt, or interpret. It executes pre-defined sequences with no perception, learning, or contextual awareness. Its ‘intelligence’ is entirely external and static.

What it changes

It changes the division of labour in factories: replacing human operators on repetitive, high-precision, or hazardous tasks. It redefines what counts as a programmable actuator in an industrial setting.

Is it worth your time

Yes—if you work in manufacturing automation, robotics history, or industrial control systems. Its evolution maps directly to shifts in programmability, power delivery, and real-time control architecture.
Same field · Robotics4 of 29
Up next in Technology

Inmarsat

1979 · 9:55

A satellite network built for ships became the world’s first lifeline for remote operations—and its compromises still define what ‘global’ really means for connectivity.

9:55